Q&A
VEX IQ Robotics Competition 2026-2027: Level Up
Marcado: G4
Welcome to the official VEX IQ Robotics Competition Question & Answer system, where all registered teams have the opportunity to ask for official rules interpretations and clarifications. This Q&A system is the only source for official VIQRC rules clarifications, and the clarifications made here from the Game Design Committee (GDC) are considered as official and binding as the written Game Manual itself.
Please review the Q&A Usage Guidelines before posting. This system is only intended for specific VIQRC game rules questions.
- For event, registration, or other competition support questions, please contact your Program Support Manager.
- For VEX technical support, contact [email protected] or [email protected].
- For game questions, suggestions, or concerns outside of specific and official rules questions, contact [email protected]
Indexação
- <G4> Pre-match setup - Is a spinning motor pre-match legal?
- Teamwork Matches Robot Starting Positions.
- Starting Position during Teamwork Challenge
- Clarification of Set Up Placement for the Tall Middle Goal for Neutral Zone
- Height IQ
- <RSC7> RESETTING Robots during a Programming Skills Match (Clarification of G4 Question)
- Using field wall to maintain starting size
- Is This Starting Position Legal?
- Important Starting Size Clarification
- Robot oversized before elimination match
- Starting Match With the Preload in the Robot
- Is it illegal to sell the CAD of a sample robot i made?
- Rule G4 Part C Clarification
- Hole counting - VEX Hexbug kits - Rule G4.c
- Clarification of the word 'Code' and Use of Libraries
- Legality of Switching Controllers Between Alliances.
- G4 clarification
- Burden of Proof at tournaments regarding G4 and G2
- G4/G5 follow up
- Ownership of Ideas when Students Move Teams G4/G5
964: <G4> Pre-match setup - Is a spinning motor pre-match legal?
G4 shows the pre-match setup rules as follows:
<G4> Pre-Match setup. At the beginning of a Match, each Robot must meet the following criteria:
-
Only be contacting the Floor and / or the Field perimeter (i.e. not contacting any Balls, other Field Elements, or other Robots).
-
Fit within an 11” x 19” (279.4mm x 482.6mm) area, bounded by one of the Starting Positions.
-
Be no taller than 15” from the Floor.
There is no mention of motor run status in this rule, based on this absence, can you please confirm that a motor is allowed to spin pre-match as long as the full text of G4 is otherwise followed? Examples included 'spinning up' a ball collector, flywheel, conveyor belt, etc.
Respondido por committee
No, this would not be permissible.
Although rule G12 primarily refers to the end of a Match, part "c" and the Note can be applied to further understand this ruling:
c. This rule’s intent is for Driver inputs and Robot motion to cease at the end of the Match. A pre-programmed routine which causes the Robot to continue moving after the end of the Match would violate the spirit of this rule. Any Scoring which takes place after the Match due to Robots continuing to move will not count.
Note: Using a motor’s built-in “Hold” function, such as to remain Hanging, is permissible.
Generally speaking, any time outside of the 60-second Match should be viewed as a "disabled" period, wherein the Robot is not moving and/or responding to any input from its Drivers.
957: Teamwork Matches Robot Starting Positions.
Our question is regarding the starting positions of the robots in Teamwork Matches. We are an event partner and many teams were asking about starting positions for their robot. In the game manual, It does address robot starting positions for Live Remote Matches in rule <LRT6> along with figure 23. But there is no such rule for on-site teamwork matches. The only documentation that addresses starting positions is on page 8 of the game manual (Starting Position) where the Figure 17 shows 2 robots on opposite sides of the field, but the actual wording doesn't state that robots must start on opposite sides of the field. Thus, the item in question is whether alliances can start both robots on the same side of the field. Thank you!
Robots must begin Live Remote Matches, in one of the highlighted Starting Positions depicted below. In addition, only one Robot from the Alliance may start on a given side of the field, as shown in Figure 23; i.e. one Robot must start on the “audience side”, and one Robot must start on the “Driver Station side”
Respondido por committee
Please review the Q&A Usage Guidelines before posting, specifically point 2, "Read and search existing Q&As before posting". We believe the following previously answered post answers your question; if it does not, please feel free to rephrase and re-submit.
884: Starting Position during Teamwork Challenge
I am looking for confirmation on how we are reading the definition of "Starting Position" and <G4> Pre-Match setup, at the beginning of a match. "Any one of the designated 11x19" volumes of the field where robots must start the match." No mention, in the definition or in <G4>, is made about robots needing to be on opposite sides or opposite halves (divided by the Low Bar).
The confusion is that all images of robots in starting positions in the game manual show the two teamwork robots starting along opposite long sides and on different sides (not on the same side of Low Bar). We believe that the images are NOT to be interpreted as a requirement or limitation for where each team may choose to start the match.
Meaning, let us consider Starting Positions to be named #1 - #8. If Team #1 chooses to setup their robot in Spot #1, Team #2 could choose to setup their robot in any of the other 7 "Starting Position"(s), including the spot that may be adjacent to Spot #1 where Robot #1 choose to start.
Is this reading of the rules correct?
Respondido por committee
The confusion is that all images of robots in starting positions in the game manual show the two teamwork robots starting along opposite long sides and on different sides (not on the same side of Low Bar). We believe that the images are NOT to be interpreted as a requirement or limitation for where each team may choose to start the match.
Meaning, let us consider Starting Positions to be named #1 - #8. If Team #1 chooses to setup their robot in Spot #1, Team #2 could choose to setup their robot in any of the other 7 "Starting Position"(s), including the spot that may be adjacent to Spot #1 where Robot #1 choose to start.
Is this reading of the rules correct?
Yes, this is correct, in a Teamwork Challenge Match. The examples shown in the field images are just meant to represent one possible starting configuration.
As a side note, however, please note that this is only true for the Teamwork Challenge. When competing in a Live Remote Tournament, rule LRT4 applies:
<LRT4> At the beginning of a Live Remote Match, the setup criteria listed in rule <G4> still applies. However, only one Robot from the Alliance may start in each pair of the Starting Position options depicted in Figure 22; one Robot must start on the “audience side”, and one Robot must start on the “Driver Station side”.
881: Clarification of Set Up Placement for the Tall Middle Goal for Neutral Zone
Our team has noticed after working on some Autonomous Programs that the tall Neutral Middle Goal placement is different from several Vex posted sites. Please clarify the placement and orientation and which document is authoritative.
I'm also an EP and we are hosting an event on Oct 23. I already have printed field reset papers for volunteers using the light gray with foam tiles lines shown on the bottom right side of the image attached. Just wanted to note that this image is easier to follow for volunteers to decide the correct placement.

Respondido por committee
Edit 2021-12-07: The v2.2 Game Manual update included the following “red box” addition to rule <G19>. We sincerely apologize for any inconvenience and confusion caused by this inconsistency.
Prior to version 2.2 of the Game Manual (released December 2021), there have been conflicting interpretations of the correct Mobile Goal rotation in the official game documentation. The layout defined in Figure 20 above, and Appendix A, in version 2.2 (or later) of the Game Manual is the only correct variation. This layout takes precedent over any other variations found elsewhere, such as other figures, websites, videos, etc that were created prior to December 2021.
Here are some ways to visualize the correct orientation, using the V-shaped vision target as the “front” of the heptagon, and the rectangular vision target as the “back” of the heptagon:
• The Alliance Mobile Goals that rest on the Platforms are “pointing towards” their respective Platform
• The Alliance Mobile Goals that begin on the AWP Line are “pointing towards” the Neutral Zone
• The outer two Neutral Mobile Goals are ”pointing towards” the field perimeter walls
• The center Neutral Mobile Goal is “pointing up”, when viewed from the audience perspective, or “pointing left” when viewed from the red Alliance Station
755: Height IQ
Can the robot height be more than 15 inches? or is it just at the start at 15 and then can extend further when match begins?
Respondido por committee
Please review the Q&A Usage Guidelines before posting, specifically point 3, "Quote the applicable rule from the latest version of the manual in your question". Often, you'll find that by quoting the rule, you'll answer your own question.
Robot height is governed by rule G4, which reads as follows, with a few portions bolded for emphasis:
<G4> Pre-match setup. At the beginning of a Match, each Robot must meet the following criteria:
Only be contacting the Floor and/or the field perimeter.
Fit within an 11” x 19” (279.4mm x 482.6mm) area, bounded by the Starting Positions.
Be no taller than 15” from the Floor.
An offending Robot will be removed from the Match at the Head Referee’s discretion. They will not receive a Disqualification, but they will not be permitted to play in the Match.
Note 1: Robots must be placed on the field promptly. Repeated failure to do so could result in a violation of <G1>.
Note 2: Robots may expand beyond their starting size constraints after the start of the Match.
The exact definition of the term “promptly” is at the discretion of the Head Referee and the Event Partner, who will consider event schedule, previous warnings or delays, etc. Once the Match starts, expansion is unlimited.
If this does not answer your question, please feel free to rephrase and re-submit.
707: <RSC7> RESETTING Robots during a Programming Skills Match (Clarification of G4 Question)
This question was asked and answered, but I need some clarification please.
"G4 839A 2 weeks ago Rule G4 Pre-match setup states that at the beginning of a Match, each Robot must meet the following criteria: 1. Only be contacting the Floor and/or the field perimeter; 2. Fit within an 11” x 19” (279.4mm x 482.6mm) area, bounded by the Starting Positions; 3. Be no taller than 15” from the Floor. Rule R5 restates similar conditions. Rule RSC1 states standard rules apply in most cases. All rules and scoring from previous sections apply to the Skills Matches, unless otherwise specified.
Our understanding of these rules are that the robot must fit within the dimensions specified above at the start of each match in one of the 2 designated starting positions. There are no other rules that states otherwise for autonomous skills matches. However, we were asked to change our autonomous skills routine during our last competition by one of the judges as they stated the robot must fit within the starting dimensions every time we launch a new routine in the starting area. Please clarify if we correctly interpreted that the starting dimensions applies to only the first launch at the beginning of an autonomous skills run or if it in fact applies to all subsequent launches in the starting position.
Answered by Game Design Committee Our understanding of these rules are that the robot must fit within the dimensions specified above at the start of each match in one of the 2 designated starting positions. There are no other rules that states otherwise for autonomous skills matches.
This interpretation is correct.
<RSC7> Handling Robots during a Programming Skills Match. A Team may handle their Robot as many times as desired during a Programming Skills Match. a. Upon handling the Robot, it must be immediately brought back to any legal Starting Position. i. Drivers may reset or adjust the Robot as desired from this position, including pressing buttons on the Robot Brain or activating sensors.
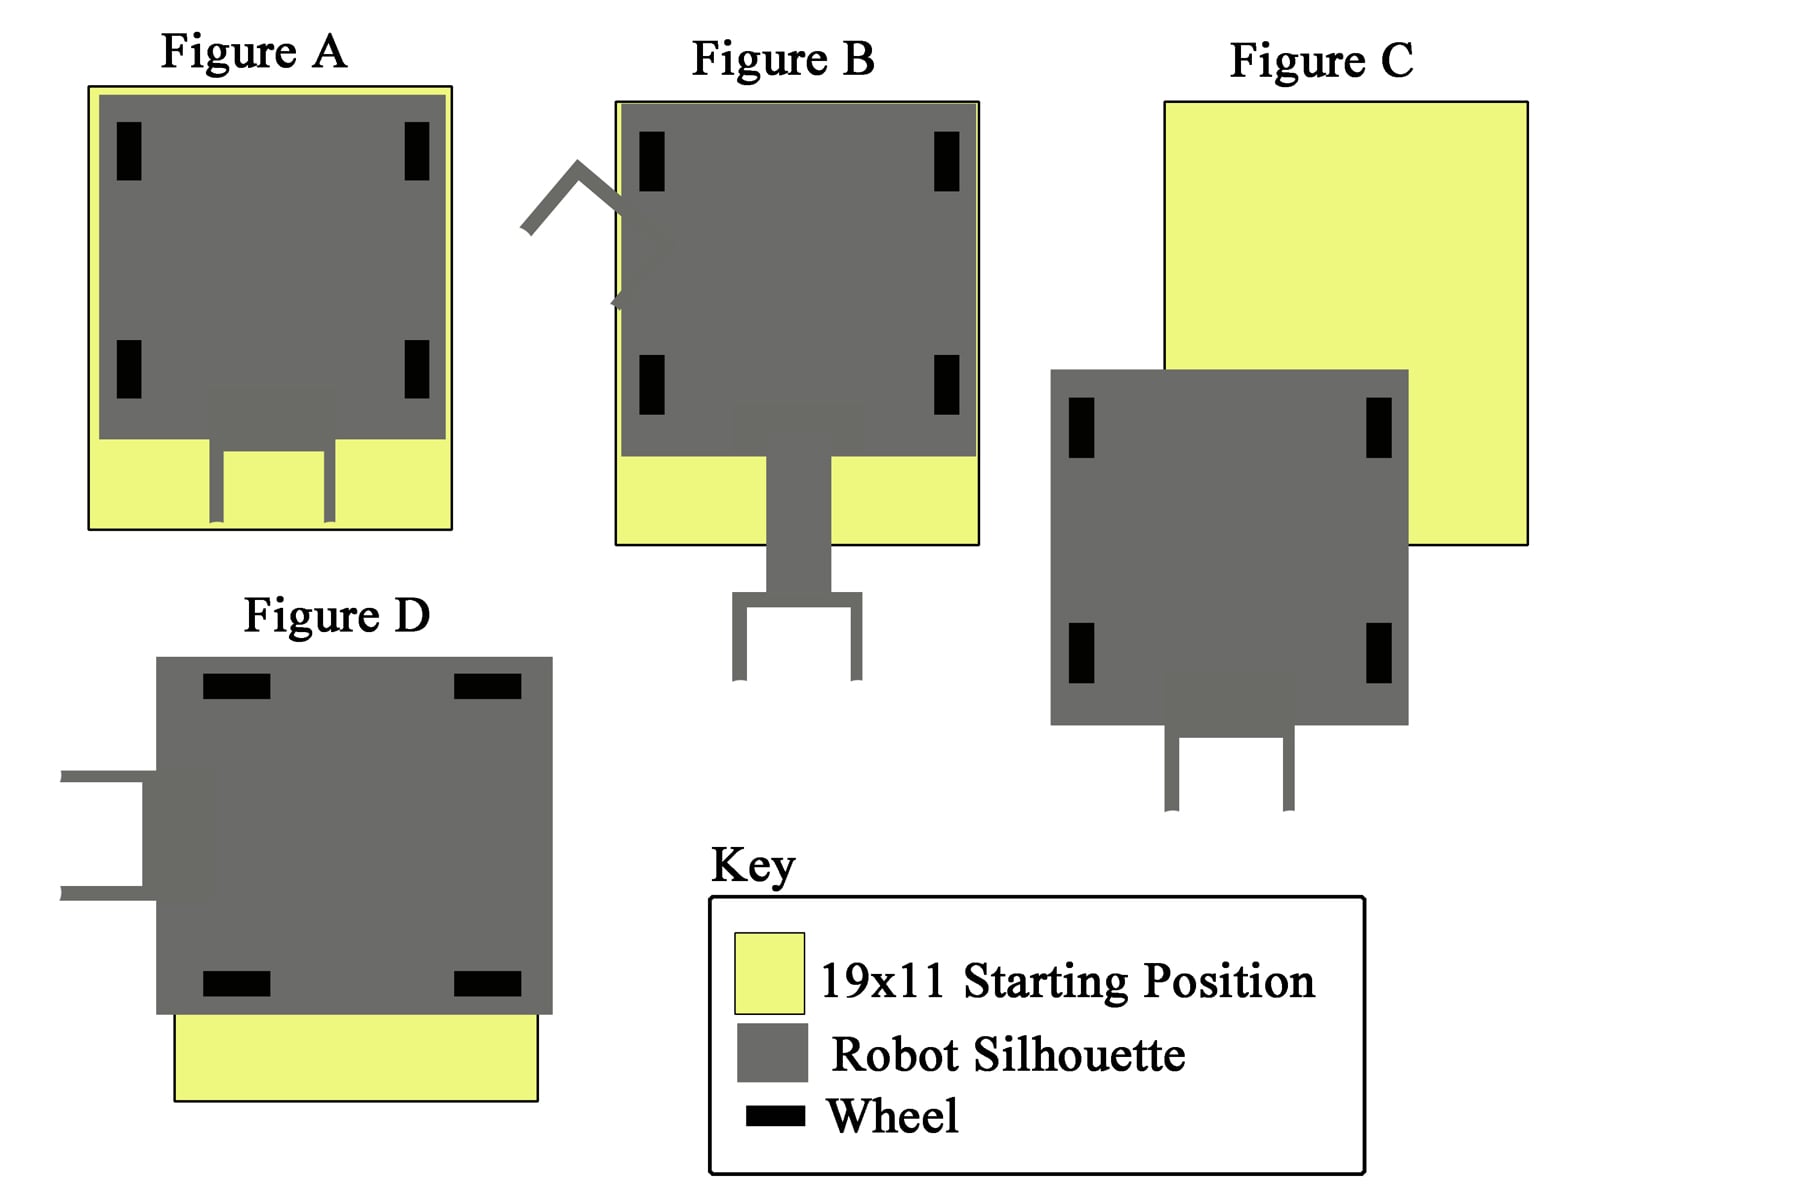
My clarification question; When a team returns their robot to a starting position during a programming skills run, do they have to return it to the 19X11X15 size every time they reset the robot? Or do they have to just have it be the 9X11X15 size the first time they are in the starting position at the start of the match? If they do not have to return to the 19X11X15 size, are all of these positions (A-D, see image) legal when resetting the robot during a robot skills match?
Respondido por committee
The definition of Starting Position reads as follows:
Starting Positions – The two (2) designated 11” x 19” (279.4mm x 482.6mm) volumes of the Field where Robots must start the Match. Starting Positions are bounded by the inner edges of the long black lines, outer edge of the short black line, and the inner edge of the field perimeter. See Figure 2 for more details.
RSC7 states that Robots must be brought back to a Starting Position (i.e. the 11"x19" volume where the Robot started the Match). The requirement for a Robot to be completely confined within this volume (i.e. rule G4) only apply during pre-Match setup, as noted in Note 2 of G4.
Therefore, all four hypothetical scenarios in your attached image would be considered legal RSC7 repositioning. With that being said, we would advise Teams to err closer to the side of Figures A, B, and D, in the interest of making it abundantly clear to the Head Referee that you have returned to the Starting Position.
646: Using field wall to maintain starting size
Relevant rule segments: <G4> Using Field Element, such as the field perimeter wall, to maintain starting size is only acceptable if the Robot would still satisfy the constraints of <R5> and pass inspection without the Field Element.
<R5> Robots must fit in a sizing box. At the beginning of any Match, Robots must be smaller than 18” (457.2 mm) long by 18” (457.2 mm) wide by 18” (457.2 mm) tall. a. Robots may expand beyond their starting size constraints after the start of a Match. b. Any restraints used to maintain starting size (i.e. zip ties, rubber bands, etc.) MUST remain attached to the Robot for the duration of the Match.
Would it be a correct interpretation of G4 to allow: A robot mechanism that needs the field perimeter to stay within the size constraints but can be temporarily constrained for inspection purposes with a mechanism assuming the mechanism will not be in place during a match. The temporary mechanism in this case would still be attached to the robot but not engaged at the beginning of the match, as the field perimeter would be holding the robot in size.
Respondido por committee
No, this would not be legal. This would be considered a possible violation of R3 parts "a" and "b", which state:
<R3> Robots must pass inspection. Every Robot will be required to pass a full inspection before being cleared to compete. This inspection will ensure that all robot rules and regulations are met. Initial inspections will take place during team registration/practice time.
a. Significant changes to a Robot, such as a partial or full swap of Subsystem 3, must be re-inspected before the Robot may compete again.
b. All possible functional Robot configurations must be inspected before being used in competition.
This hypothetical question represents a Robot with two functional configurations, one of which would pass inspection, and one of which would not.
588: Is This Starting Position Legal?
I have a question about the starting position in the VEX IQ skill challenge.
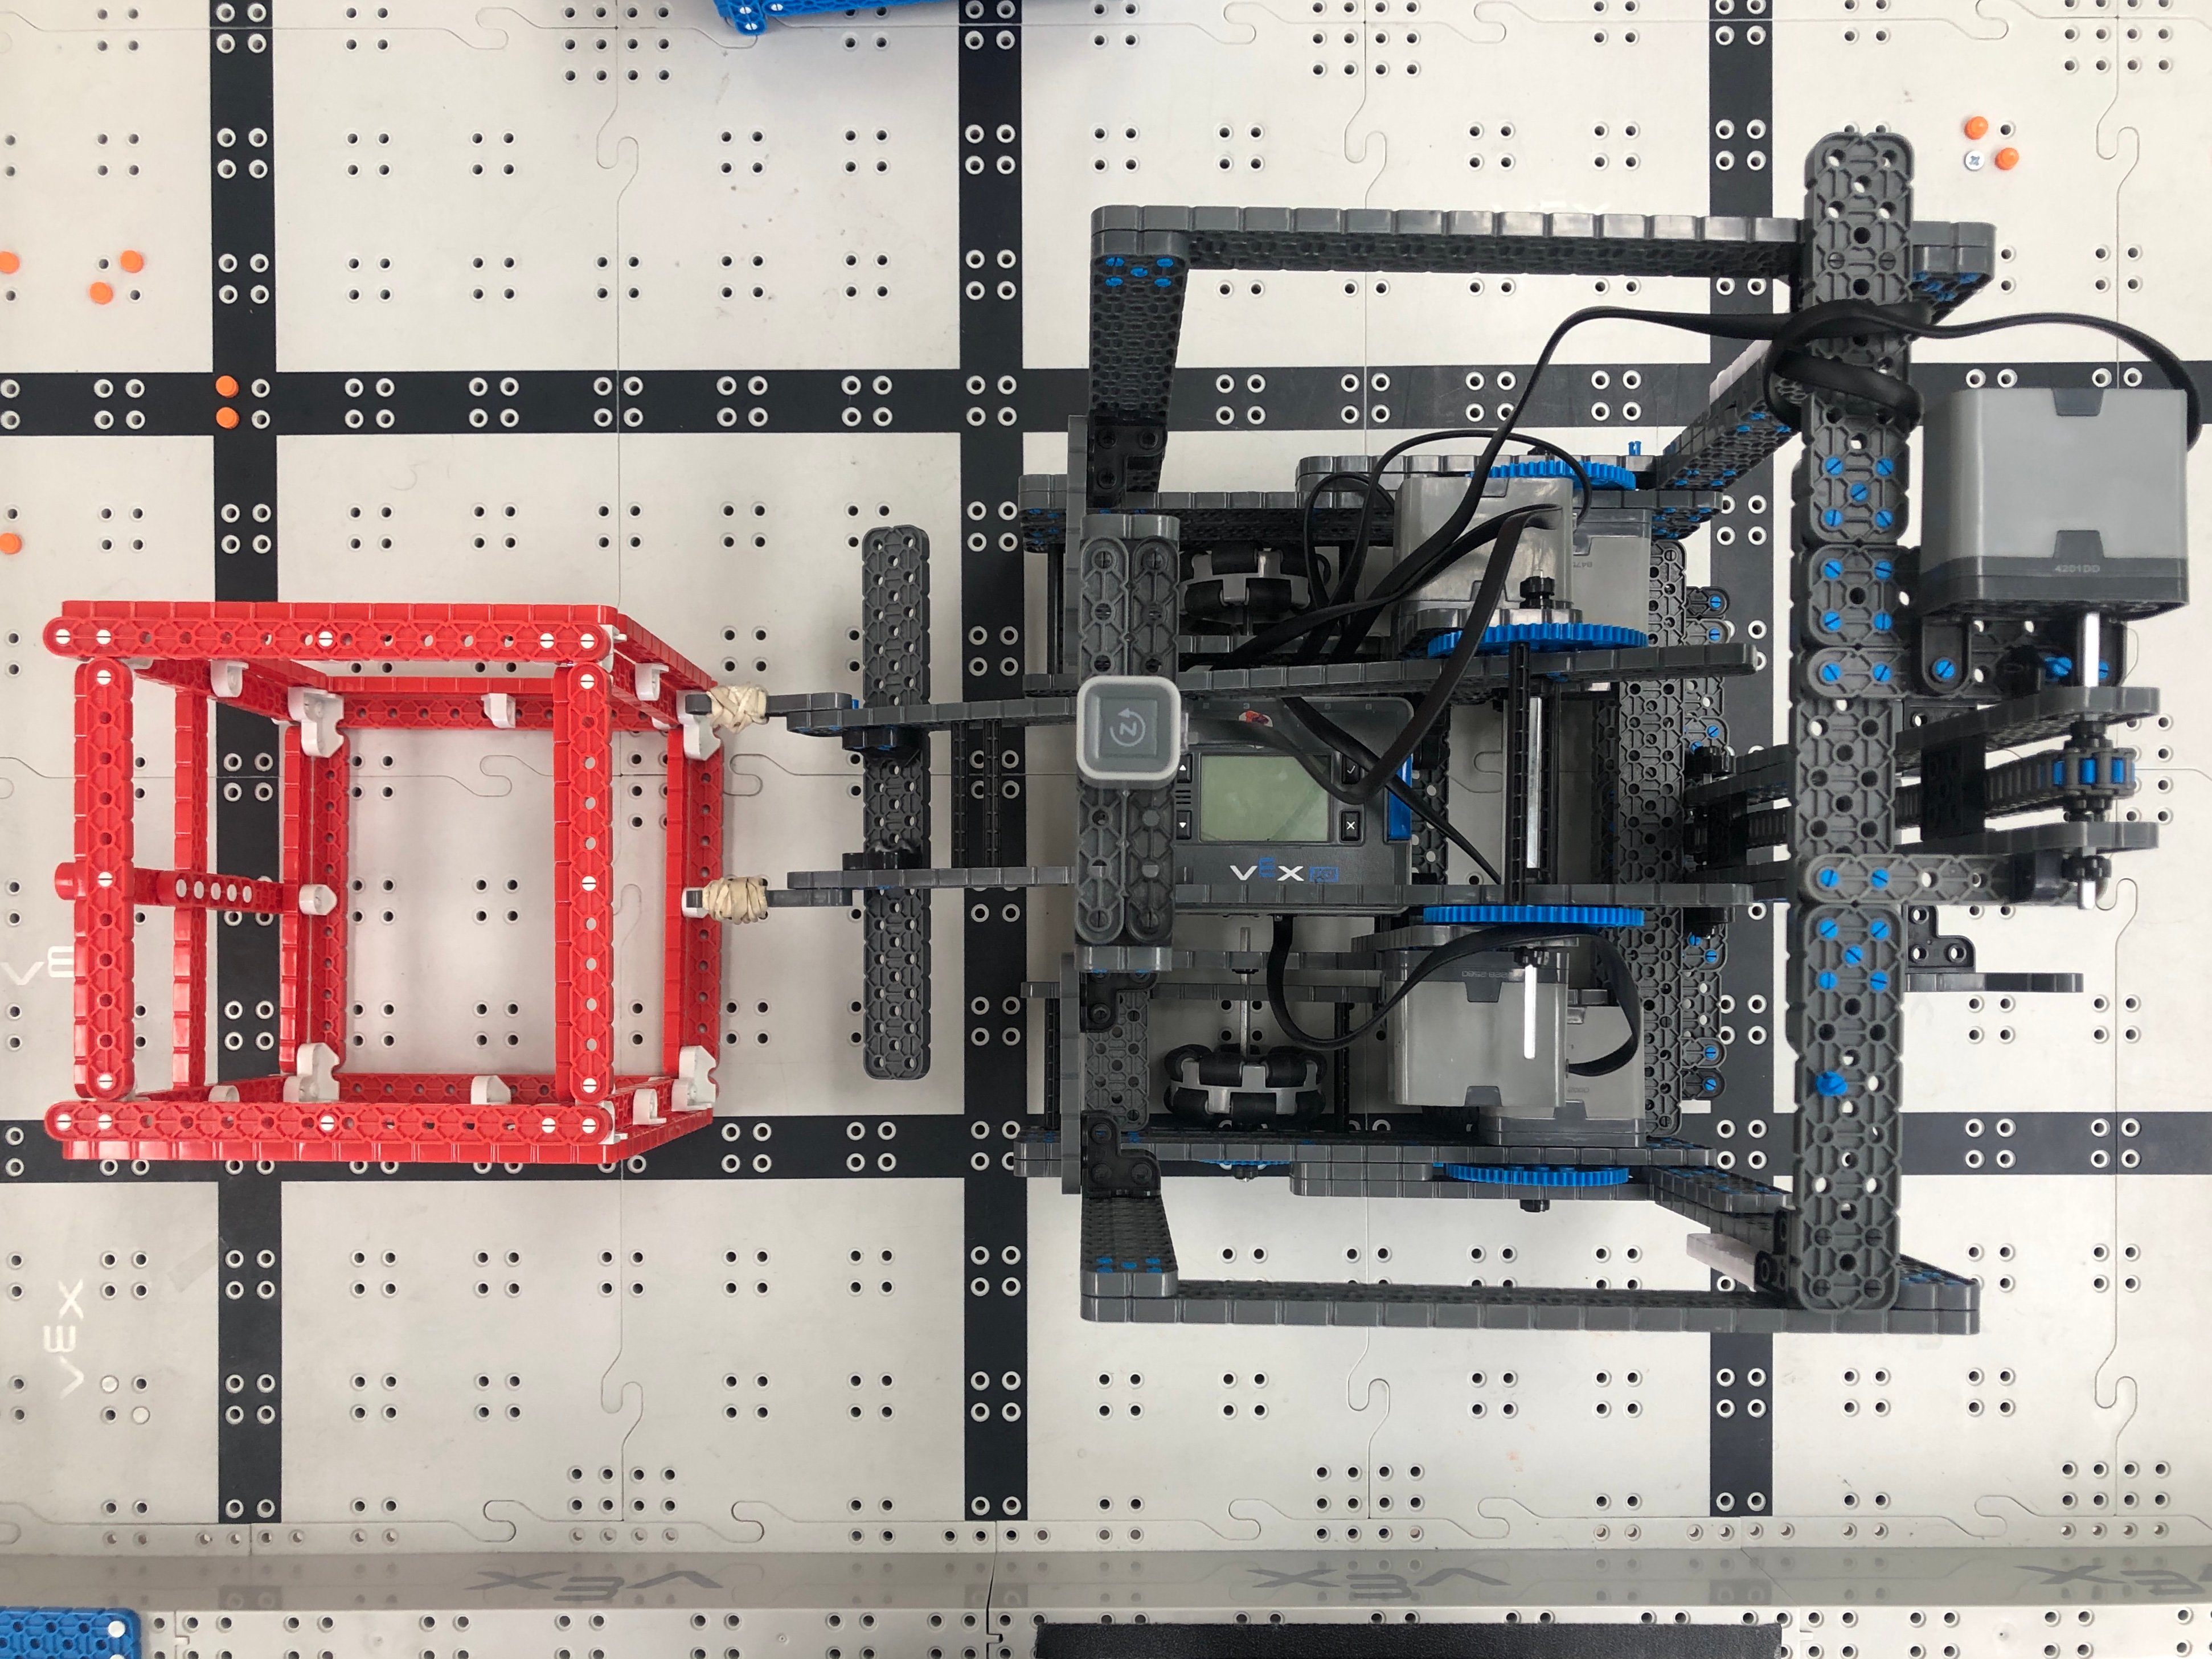
During the program skill challenge, If my robot start in the position below, is it legal? The driving base is within the starting position, the arm is longer, but not touching the the cube.
Respondido por committee
Thank you for providing an image to help clarify your question. However, please review the Q&A Usage Guidelines, specifically point 3, "Quote the applicable rule from the latest version of the manual in your question.". The definition of Starting Position, and rule G4, are quoted as follows:
Starting Position - The two (2) designated 11” x 19” (279mm x 482.6mm) spots on the field where Robots must start the Match. Starting Positions are bounded by the inner edges of the long black lines, outer edge of the short black line, and the inner edge of the field perimeter. See Figure 2 for more details.
<G4> Pre-match setup. At the beginning of a Match, each Robot must meet the following criteria: a. Only be contacting the Floor and/or Field Perimeter. **b. Fit within an 11” x 19” (279.4mm x 482.6mm) area, bounded by the Starting Position. ** c. Be no taller than 15” from the Floor.
The Robot in the photo you have referenced extends past the inner edges of the long black lines in the Starting Position, and would therefore not be legal.
One "thought experiment" to help determine if a Robot is within the Starting Position would be to imagine a spotlight shining down on the Robot - if its shadow would fall within the Starting Position, then it is legal. This similar Q&A provides another test that Head Referees can perform before a Match:
for a Robot which pushes the limit of allowable size, a measuring tool could be as simple as sliding a VEX IQ beam or plate along the edges of the Starting Position. (the crossbar of the VEX IQ Challenge Sizing Tool, turned vertically, could also be used)
This answer is the same for Teamwork Challenge, Driving Skills Challenge, and Programming Skills Challenge Matches.
580: Important Starting Size Clarification
<G4> Robots begin the Match in the starting volume. At the beginning of a Match, each Robot must be smaller than a volume of 18” (457.2 mm) long by 18” (457.2 mm) wide by 18” (457.2 mm) tall. Using Field Elements, such as the field perimeter wall, to maintain starting size is only acceptable if the Robot would still satisfy the constraints of and pass inspection without the Field Element. Robots in violation of this limit will be removed from the field prior to the start of the Match, at the Head Referee’s discretion.
<R4> Robots must fit in a sizing box. At the beginning of any Match, Robots must be smaller than 18” (457.2 mm) long by 18” (457.2 mm) wide by 18” (457.2 mm) tall.
Q&A 439 https://events.vex.com/VRC/2019-2020/QA/439 Q&A 423 https://events.vex.com/VRC/2019-2020/QA/423
Although you have answered questions about starting size in the past (see q&a's listed above), we are still a bit confused on the legality of the situations drawn below.
A & B: The robot itself is in size, but the preload is out of 18” (length wise)
C : The robot itself is out of size (height wise because of its tray), while the preload is inside of the robot
We are mainly concerned with this: if you were to put the preload into your robot and by doing so it forces a section of your robot out of the 18"x18"x18" size (as seen in scenario C where the tray was forced outside by the preload), would that be a legal starting position. If you could clarify which starting positions are considered legal that would be very helpful. Thank you!

Respondido por committee
First, thank you for quoting the relevant rules, searching for similar Q&A posts, and providing a clarifying image.
A & B: The robot itself is in size, but the preload is out of 18” (length wise)
These would both be legal. These are both scenarios that were intended to be covered by Q&A 439, as linked.
C : The robot itself is out of size (height wise because of its tray), while the preload is inside of the robot
This would not be legal.
Another way to word the response from Q&A 439 would be as follows:
G4 and R4 are intended to refer to Robot size only. The word 'Robot' refers to the VEX definition of 'Robot': "Anything that has passed inspection that a Team places on the field prior to the start of a Match." An inspection-passing Robot consists of VEX metal, wheels, gears, electronics, etc.
The hypothetical Robot C may have passed inspection (and therefore satisfied R4). Once it is placed on the field, the Head Referee is now checking its compliance with G4. Since some portion of the metal, wheels, gears, and electronics that make up the 'Robot' are now outside of the 18" x 18" x 18" size restriction, it is now in violation of G4.
512: Robot oversized before elimination match
at a previous event we ran into an issue where a robot had passed inspection, and after competing all day, the robot was over sized, it was minimal, but still over sized. during the elimination rounds a sizing inspection was requested. So, how should this handled Is the robot DQ'd Per R2e, or as discussed in R2d, the robot sits out, until it can be fixed. R2e states "During" the match. this was caught before match started.
G4 States: Robots in violation of this limit will be removed from the field prior to the start of the Match, at the Head Referee’s discretion. This is what was done. But during elimination match if it is a DQ, then the whole alliance is DQ'd.
Respondido por committee
Please review the Q&A Usage Guidelines, specifically point 3, "Quote the applicable rule from the latest version of the manual in your question.".
Rule R2 reads as follows, with the relevant portions bolded for emphasis:
<R2> Robots must pass inspection. Every Robot will be required to pass a full inspection before being cleared to compete. This inspection will ensure that all robot rules and regulations are met. Initial inspections will take place during team registration/practice time. a. Significant changes to a Robot, such as a partial or full swap of Subsystem 3, must be re-inspected before the Robot may compete again.
b. All possible functional Robot configurations must be inspected before being used in competition.
c. Teams may be requested to submit to random spot-inspections by event personnel. Refusal to submit will result in Disqualification.
d. Robots which have not passed inspection (i.e. who are in violation of one or more Robot rules) will not be permitted to play in any Matches until they have done so. <T2> will apply to any Matches that occur until the Robot has passed inspection.
e. If a Robot has passed inspection, but is later found to be in violation of a Robot rule during a Match, then they will be Disqualified from that Match and <R2d> will apply until the violation is remedied and the Team is re-inspected.
G4 reads as follows:
<G4> Robots begin the Match in the starting volume. At the beginning of a Match, each Robot must be smaller than a volume of 18” (457.2 mm) long by 18” (457.2 mm) wide by 18” (457.2 mm) tall. Using Field Elements, such as the field perimeter wall, to maintain starting size is only acceptable if the Robot would still satisfy the constraints of <R4> and pass inspection without the Field Element. Robots in violation of this limit will be removed from the field prior to the start of the Match, at the Head Referee’s discretion.
The scenario as you have described would be considered a G4 violation, because it occurred prior to a Match starting. R2-e explicitly only references a violation that is caught during a Match. Therefore, this would not be considered a Disqualification, and R2-d would then apply for that Match and any subsequent Matches. R2 and G4 apply regardless if the Matches are Qualification Matches or Elimination Matches.
439: Starting Match With the Preload in the Robot
Good evening,
I have a question regarding the preload and how it may affect sizing at the beginning of the match. While reading R4 and G4, the rules state that the robot must be in the 18x18x18 constraint at the beginning of the match without mention of the preload. In Virginia tournaments, however, teams who are resized on the field are allowed to remove their preload and be measured. Is it legal for the robot itself to be out of size with the preload in the robot in the beginning of the match?
Thank you, Korvex Robotics
Respondido por committee
Good morning. Please see this similar Q&A, which states that the Preload is not intended to be used when considering Robot size as it pertains to G4 and R4.
3203: Is it illegal to sell the CAD of a sample robot i made?
If i made a CAD model of a concept robot that is made up of sample mechanisms. And sell it to teams for inspiration to help them see what a concept could look like, would this be allowed.
Respondido por committee
This is a violation of the Global Robotics & Science Foundation Student Centered Policy & Code of Conduct.
This is not allowed in the VEX Robotics Competitions, and would be considered a violation of, at the least, G1 and G2.
Any further questions on this topic can be directed to [email protected]
3058: Rule G4 Part C Clarification
The Judge Advisor and I keep going back and forth as to whether or not using the Hero Bot with no modifications to it should be a violation or not during inspection.
Rule G4, part C states: Teams may use Robot plans and code (e.g., the annual Hero Bot, VEXcode configurations, etc.) provided by VEX Robotics or the RECF, but are encouraged to use these Robots, mechanisms, and code only as a starting point that Students modify, improve, or replace as their skills increase. Plans provided by VEX Robotics or the RECF are the only legal plans available for use in competition.
Would a team be in violation if they were to build a Hero Bot with no modifications? I would say yes that it is a violation if you're just copying the robot and not making it your own. Just removing the sensors from the Hero Bot shows that it's no longer an exact copy.
Rule G4 part C suggests that teams can use the Hero Bot as a starting point. It seems that if teams are struggling to come up with a design, here's a design to get you started. The rule continues to say "that Students modify, improve, or replace as their skills increase," which seems that students should modify the robot to make it their own.
The other parts of Rule G4 state the following: Part A: Teams must avoid academic dishonesty and should not copy a Robot or mechanism that has been provided for them. Part B i and ii: Mentions that Using elements of another design as a starting point is acceptable as long as the team makes the design uniquely their own or else it will be in violation.
The Hero Bot is provided by VEX Robotics or the RECF, and so these are legal plans available for use in competition. Does copying the Hero Bot override everything else that's said about copying a robots design stated in Rule G4 part A and B?
Any clarification/thoughts would be greatly appreciated.
Thank you!
Respondido por committee
G4c. Teams may use Robot plans and code (e.g., the annual Hero Bot, VEXcode configurations, etc.) provided by VEX Robotics or the RECF, but are encouraged to use these Robots, mechanisms, and code only as a starting point that Students modify, improve, or replace as their skills increase. Plans provided by VEX Robotics or the RECF are the only legal plans available for use in competition.
<G4> clause C, included above, acts as an exception to the rule. Note that Teams are encouraged to use these Robots, mechanisms, and code only as a starting point; Teams are not required to do so.
Teams are allowed to use Hero Bots and code provided by VEX Robotics or the RECF with or without modification, even if multiple Teams in an organization choose to use the same Hero Bot design.
2997: Hole counting - VEX Hexbug kits - Rule G4.c
I use the term "hole count" to mean "create an exact duplicate of a Mechanism, groups of Mechanisms, up to and including the entire Robot. "
Settled law says that teams may hole count any prior VEX IQ herobot designs. (i.e Huey, Allie, Clawbots, etc.) See G4.c
The VEX HEXBUG Robotics line uses VEX IQ parts and were created by VEX engineers. (Or IQ uses HEXBUG parts) Some of these parts are not part of the bundled Education or Competition kits or not sold as a separate SKU. They are in the allowed parts list. The HEXBUG kits come with instructions on how to use those parts. (Kits range from the simple like the road racer, to the complex like the Off Road Vehicle. )
Since those instructions / designs also come from VEX are those designs allowed to be hole counted? Can you elaborate on how you got to the answer.
Respondido por committee
As described in clause C of of rule <G4>,
Teams may use Robot plans and code (e.g., the annual Hero Bot, VEXcode configurations, etc.) provided by VEX Robotics or the RECF, but are encouraged to use these Robots, mechanisms, and code only as a starting point that Students modify, improve, or replace as their skills increase. Plans provided by VEX Robotics or the RECF are the only legal plans available for use in competition.
HEXBUG* Build Instructions that were published by VEX Robotics (e.g., the Robotic Strandbeast---a particular favorite of multiple GDC members) are legal plans for use in competition, but as with any other VEX-provided plan Teams are encouraged to modify the plan to make it their own.
Mechanical/structural components from the VEX Robotics by HEXBUG* product line are made legal for use in Robot construction in clause D of rule <R16>. As described in clause F of rule <R15>, electrical components from the VEX Robotics by HEXBUG* line are prohibited on VIQRC Robots.
*The HEXBUG brand is a registered trademark belonging to Spin Master Corp
2964: Clarification of the word 'Code' and Use of Libraries
With the update of the G4 rule on 12/4/25, it says to reference the RECF document on student centered and non- student centered examples for further clarification of G4 violations. As we read through this, it says that "Students should be able to understand and explain the code, and students should be able to demonstrate that they can program on a level equivalent to the code used in their mechanism." It also states, "Students that use publicly available custom libraries or functions are also capable of creating their own custom libraries and functions." Now when we read through the the non-student centered examples, it states "Students are unable to explain the code functionality or development without a mentor’s assistance", and "Students use a publicly available custom library developed by another team, but cannot create their own custom libraries".
Our question is this, if a team uses a public library like Lemlib or other libraries and can create their own libraries, are they in violation of G4? If a student uses Lemlib as a starting point, but then builds off of it or is able to explain it's use in detail, are they safe? We are needing a little more clarification as to what is being looked or is expected from teams within their code. There are a lot of teams that use Lemlib or other libraries around the world and we feel that the current explaination is confusing/contradictory. Referencing Q and A 2823, it says that students should be able to 'explain' but in the RECF reference document is seems contradictory. Can we get more clarification?
Respondido por committee
If asked to defend their work, the Team must be able to demonstrate that they understand their code and have the ability to independently create code similar to that used for their Robot at the event. Because experience and understanding varies between volunteers and events, we cannot provide blanket guidance on the level of demonstration that should be requested or required, and we can't pre-categorize Teams as "in Violation" and/or "safe." Event staff must discuss all reported <G4> Violations with their RECF Regional Support Manager, who will provide guidance on a case-by-case as needed.
2937: Legality of Switching Controllers Between Alliances.
123A and 321A are on the same alliance during a match. During the driver control period, a drive team member from 123A is handed a controller for 321A's robot.
- Can alliances intentionally swap controllers with their alliance partner during the driver control period?
- If no, which rules would apply in this scenario?
Thank you for your time.
Respondido por committee
Alliance Partners cannot legally operate each other's Robots during a Match.
Swapping controllers as you've described would result in Students serving as Drive Team Members for multiple Teams during an event, or a Team borrowing a Driver from another Team, which are Violations of rule <G5>.
2930: G4 clarification
I would like to request clarification regarding how <G4> should be applied when evaluating Teams that use publicly available mechanisms (e.g., “meta-bots,” common 180-degree swing arms, etc.) as inspiration.
Specifically:
What level of iteration or modification is required for a mechanism to be considered a “unique design” under <G4>? For example, if a Team cites their source properly and can explain their design process, is modifying elements such as arm length, gear ratio, structure layout, or grip geometry sufficient to demonstrate meaningful iteration?
Would the use of a common swing-arm mechanism automatically violate <G4>, even if the Team documents inspiration and can defend their modifications? Our Head Referee is concerned that these designs may be “above the students’ skill level,” and is considering disallowing all versions of the 180-degree swing mechanism—even those with documented student-driven changes. I would appreciate guidance on whether this interpretation aligns with the intent of <G4>.
Regarding exact or near-exact copies: At what point do small changes (e.g., adjusting grip shape, modifying gears, or changing lengths) become meaningful enough to avoid being considered a direct copy?
Our goal is to apply <G4> consistently and fairly while ensuring students are encouraged to innovate rather than discouraged from using publicly known mechanisms as starting points, as long as they can defend their work.
Thank you for your clarification.
Best regards,
Respondido por committee
Thanks, Team 1599B, for these questions.
There is a difference between finding inspiration from a design or Robot mechanism and building a direct copy (hole counting) from a video or other reference. Being inspired by a design means learning from others and creating your own version of mechanisms or other elements of a build. Attempts to recreate entire Robot builds from other sources can quickly move beyond inspiration.
Student Team members are the only individuals who know their inspiration, learning, and how they worked through the engineering design process to arrive at an independent solution. As such, it is up to the Team to determine the proper level of evidence needed to prove their iteration through the engineering design process.
To more directly answer your questions:
What level of iteration or modification is required for a mechanism to be considered a “unique design” under G4? Regarding exact or near-exact copies: At what point do small changes (e.g., adjusting grip shape, modifying gears, or changing lengths) become meaningful enough to avoid being considered a direct copy?
Similar mechanisms built independently by different Teams will reflect different choices and utilize different parts and spacing and would not represent <G4> Violations. However, using an exact copy of a popular mechanism may raise questions about whether the mechanism represents the Team's work, and may lead to penalties for a <G4> Violation.
If asked to defend their work, the Team must be able to demonstrate that they created their own version of the Robot or mechanism that inspired them. Because experience and understanding varies between volunteers and events, we cannot provide blanket guidance on the level of iteration or modification that should be requested or required. Event staff must discuss all reported <G4> Violations with their RECF Regional Support Manager, who will provide guidance on a case-by-case as needed.
Would the use of a common swing-arm mechanism automatically violate G4, even if the Team documents inspiration and can defend their modifications?
There is no mechanism that should be considered an "automatic" <G4> Violation if the Team is able to defend their work as their own.
2867: Burden of Proof at tournaments regarding G4 and G2
(This is a hypothetical situation, this is not a real team or people) This question is asked by us because as the season ramps up we see teams often have members that occasionally may have to miss competition.
Imagine team 1234A, who has a extremely advanced positioning algorithm that uses a wide variety of sensors, and does complex calculations in code to estimate values. This is the Schrödinger location system. 1234A has 4 members Alice-Driver Bailey-Builder Carson-Coder Dom-Designer
Scenario 1: Team 1234A is at a event, but only Alice and Bailey are at the competition (Carson and Dom are unable to attend maybe due to travel, sickness, etc). A judge, referee or other event staff raises concerns representing the programming of the robot representing their skill level. Team 1234A does not have a notebook (various reasons). Person A and B have zero understanding of the programming systems used, and maybe know that the Schrödinger location system allows them to locate the robot on the field, however cannot defend the code they have.
Scenario 2: Team 1234A is at a event, but only Alice and Bailey are at the competition (Carson and Dom are unable to attend maybe due to travel, sickness, etc). A judge, referee or other event staff raises concerns representing the programming of the robot representing their skill level. Team 1234A does have a notebook Bailey wrote that in great detail explains the Schrödinger location system, reasons behind its implementation, and the iterations of the software. (Basically without any doubt we can assume Carson designed and implemented said software without any outside help.) Person A and B have zero understanding of the programming systems used, and maybe know that the Schrödinger location system allows them to locate the robot on the field, however cannot defend the code they have.
For this Q and A, lets assume that there is no other evidence of Carson coding the Schrödinger location system besides the notebook in scenario 2, and scenario 1, the judges just have to believe Alice and Bailey, but Carson is on the team roster without a question.
Would Scenario 1 or 2 be a violation of <G4> given the rest of the robot is explained properly except coding?
What if 1 or more other sections, Dom's design maybe cannot be explained? Is it then a <G4>.
What would the reprecussions for violating <G4> in this case be, would they still be allowed to compete given benefit of the doubt?
Respondido por committee
Thanks, Team 1523C, for these questions.
Because events, Teams, Event Partners, Judge Advisors, and Head Referees (and their opinions and skill sets) vary widely, we're unable to provide blanket guidance for how much proof is enough when <G4> concerns are raised at an event, and we are unable to provide guidance for the hypothetical scenarios in your question beyond a couple of very basic statements.
- Your scenarios and questions highlight exactly why Teams should record all details of their research and work in an engineering notebook.
- If the Student Team members who are at the event when a <G4> concern is raised don't understand and/or cannot defend the Team's work, they risk a <G4> Violation and the resulting penalties.
2850: G4/G5 follow up
This is a followup to https://events.vex.com/V5RC/2025-2026/QA/2834
In part, the GDC's answer includes the following quote, which seems entirely unsatisfying given the potential consequences up to and including removal from the program, where the burden of proof falls on the team to defend themselves.
Neither the game manual nor the GDC provide guidelines for what should be included in a Team’s engineering notebook, should they choose to use one. We recommend that Teams review the related content in the RECF Library, including the pertinent portions of the RECF Guide to Judging.
In response to one scenario that I posted:
A team "hole counts" a mechanism based on YouTube content. The mechanism is made entirely of Vex-branded parts and is identical to the YouTube version.
The GDC's response was:
This would be a clear violation of rule <G4> clause B that could lead to penalties up to and including removal from the program if recognized by or reported to event staff.
If the team had an Engineering Notebook and in that notebook the team describe finding the video, building it, creating various iterations, before concluding that the original version (the copy of the YouTube implementation) is optimal, would that be sufficient to overcom G4.2.i
Using elements of another design as a starting point is acceptable if the Team is capable of demonstrating evidence of iteration, innovation, and/or modification that makes the design uniquely their own. Documentation should clearly demonstrate the idea that was used for inspiration, and how it was changed for the final implementation on the Team’s Robot. It should be clear that this final implementation is not an exact copy of ANY other original design.
Especially given that there are only so many permutations of reasonably combining Vex parts?
Replace "mechanism" from the original question to "drivetrain", where there seem to be a limited number of reasonable drivetrain choices. Are all teams at risk of program removal if their drivetrain is an exact copy of some other popular drivetrain?
Respondido por committee
Thanks, Team 355U, for this follow-up question.
There is a difference between finding inspiration from a design or Robot mechanism and building a direct copy (hole counting) from a video. Being inspired by a design means learning from others and creating your own version of mechanisms or other elements of a build. Attempts to recreate entire Robot builds from videos can quickly move beyond inspiration.
Student Team members are the only individuals who know their inspiration, learning, and how they worked through the engineering design process to arrive at an independent solution. As such, it is up to the Team to determine the proper level of documentation needed to prove their iteration through the engineering design process.
To more directly answer your questions:
If the team had an Engineering Notebook and in that notebook the team describe finding the video, building it, creating various iterations, before concluding that the original version (the copy of the YouTube implementation) is optimal, would that be sufficient to overcom G4.2.i
Only if the Team could demonstrate that they created their own version of the Robot or mechanism that inspired them. Hole counting is a Violation of rule <G4>, even if Teams try other thing before deciding to copy someone else's work. We'll once again state that the V5RC Game Manual and GDC do not provide guidelines for what Teams should or should not include in their engineering notebooks. That guidance can be found in the RECF Guide to Judging and the notebook judging rubric. If you have additional questions about engineering notebooks, please post them in the Judging Q&A.
Are all teams at risk of program removal if their drivetrain is an exact copy of some other popular drivetrain?
Similar drive trains built independently by different Teams will reflect different choices and utilize different parts and spacing and would not represent <G4> Violations. However, using an "exact copy of some other popular drivetrain" may raise questions about whether the drivetrain represents the Team's work, and may lead to penalties for a <G4> Violation.
2843: Ownership of Ideas when Students Move Teams G4/G5
Based on Q and A 2812, students cannot directly copy mechanisms that another team built. However, what happens to the “ownership” of the idea if a team splits legally per rule G5. Here is the following hypothetical scenario.
Amy and Bob are both on team 123A early on in the season. Together, they work together to develop the “Schrödinger” mech. Partway through the season, Bob leaves 123A to join team 123B for a legal reason described in rule G5A. Both Amy and Bob have an equal and complete understanding of the “Schrödinger” mech as per rule G5Aiii. In order to document their ideas, both teams will put all of their evidence in a physical digital engineering notebook. It should be assumed for this Q and A that the only documentation these teams have is located in their notebook. Which of the following scenarios, if any, would constitute a G4 violation?
Bob (on team 123B) builds an identical copy of the “Schrödinger” mech. Bob does this using pictures/cad drawings he took/made of the “Schrödinger” mech while still on team 123A. Both team 123A and 123B now have identical mechanisms on their robot.
a. Is this a G4 violation for either team?
b. If Bob were to recreate the “Schrödinger” mech from pictures/cad drawings that Amy took/made would this affect the legality
c. Does the answer to question B change depending on whether or not Amy or Bob wrote the entries/provided the documentation?
d. If scenario A is legal, does Bob need to provide any additional documentation in 123B’s notebook about the documentation and development of the “Schrödinger” mech or is the documentation in team 123A’s notebook sufficient?
e. If team answer to part D is that Bob does not need additional documentation of the “Schrödinger” mech, what happens if 123A forgets to bring their notebook to a competition and it is not present?
f. If the answer to part A is that this is not a G4 violation, but the answer to part C is that Bob does need additional documentation in 123B’s notebook, could 123A now potentially face a G4 violation if 123A doesn’t have complete documentation of the “schrödinger mech” but 123B does?
g. Do any of the above answers change if the number of students involved change? Such as if 123A originally had Amy, Bob, and Bill and both Bob and Bill left to make a new team.
Thank you for your time answering these detailed questions. Additionally, please let me know if you need any further clarification on any of the scenarios.
Respondido por committee
Hi, Evan. Thanks for this question and your scenarios.
The work done by a Team belongs to the Team, and the Team retains ownership of the work if one or some of its Students leave to join or form a new Team in the current season. If student B leaves the Team and wants to reproduce any of the work done by that team, it's just the same as getting inspiration from any other source. It is up to student B to prove that they were inspired by the original team's work but iterated/revised it to make it their own. Copying the old team's work directly would be plagiarism / hole counting and a <G4> violation.
However, if an entire Team leaves an organization (e.g., due to differences of opinion, relocation, etc.) and reforms with the same set of Students in a different organization, ownership of the ideas would remain with that group of Students.
To address your specific scenarios/questions:
- a & b: This would be a Violation for Bob's Team, 123B, if the Students are unable to demonstrate that they iterated/revised Team 123A's design to make it their own.
- c: This guidance remains the same regardless of which student on 123A documented the design.
- d, e, & f: N/A
- g: If any Student from the "original" Team remains on that Team, they have ownership of the Team's ideas. Rule <G4> and Clause A3 of rule <G5> apply, and the remaining Student must ensure that their skills match the level of the Robot and code.