

BlackOut
| Team Name: | BlackOut |
|---|---|
| Organization: | Robotics NorCal |
| Program: | VEX V5 Robotics Competition |
| Active: | Yes |
About the Team
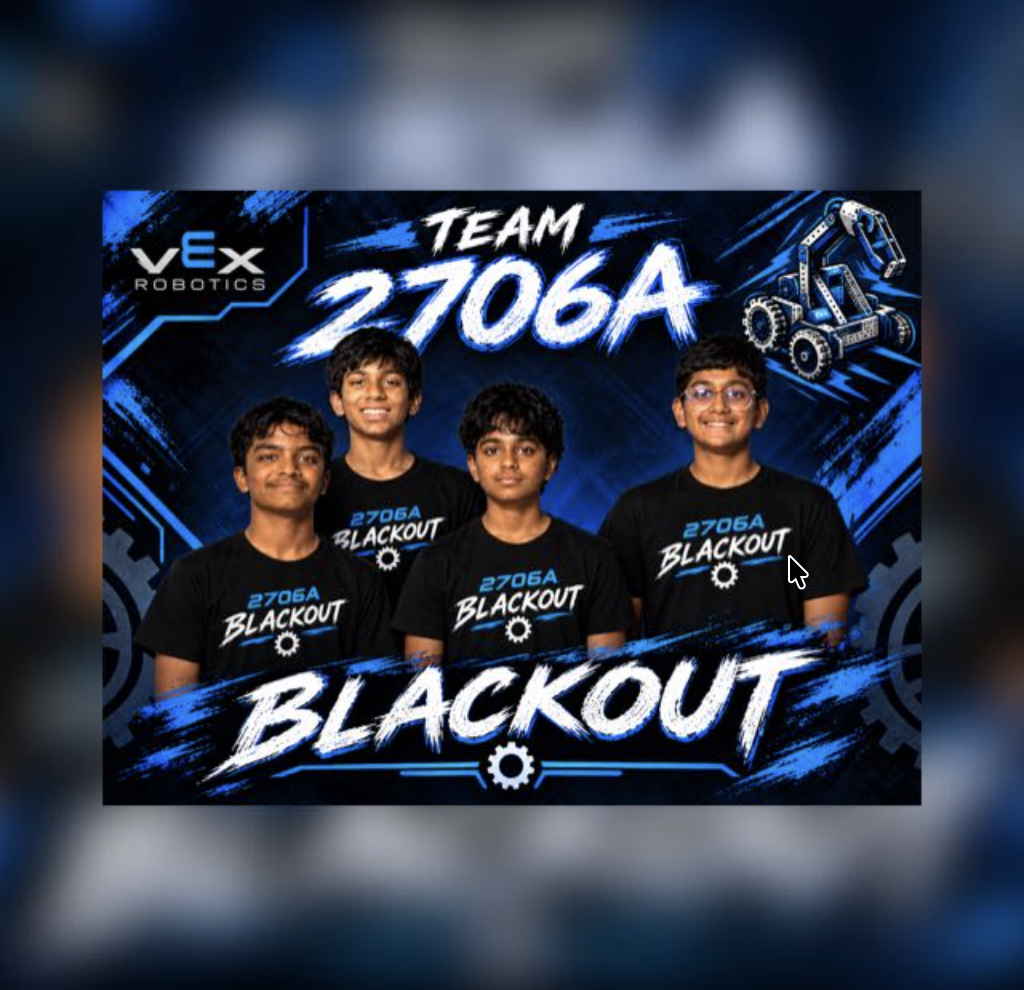
We are BlackOut, team 2706A, from Lammersville Unified School District, and we are proud to be part of the North Cal Robotics Mountain House team. There are four of us: Arnav, Ani, and Umar are in 8th grade, and Vikranth is in 7th grade. This is the first time any of us has competed in VEX, and we are all really excited to be bringing a robot to life. All four of us love building. Arnav and Vikranth are our lead designers and builders, and Arnav is also our driver. Ani and Umar are our lead scouts, which means they watch other teams’ matches so we can learn from them, and they also write the code for our robot. Everyone pitches in on keeping our notebook going. Outside of robotics, we like chess, basketball, volleyball, badminton, soccer, and dance, and some of us enjoy designing things on the computer. Our mentor, Joseph Lipper, taught us the basics at his summer camp. Since then, most of what we know we have figured out ourselves by trying things, making mistakes, and trying again.
About this Season
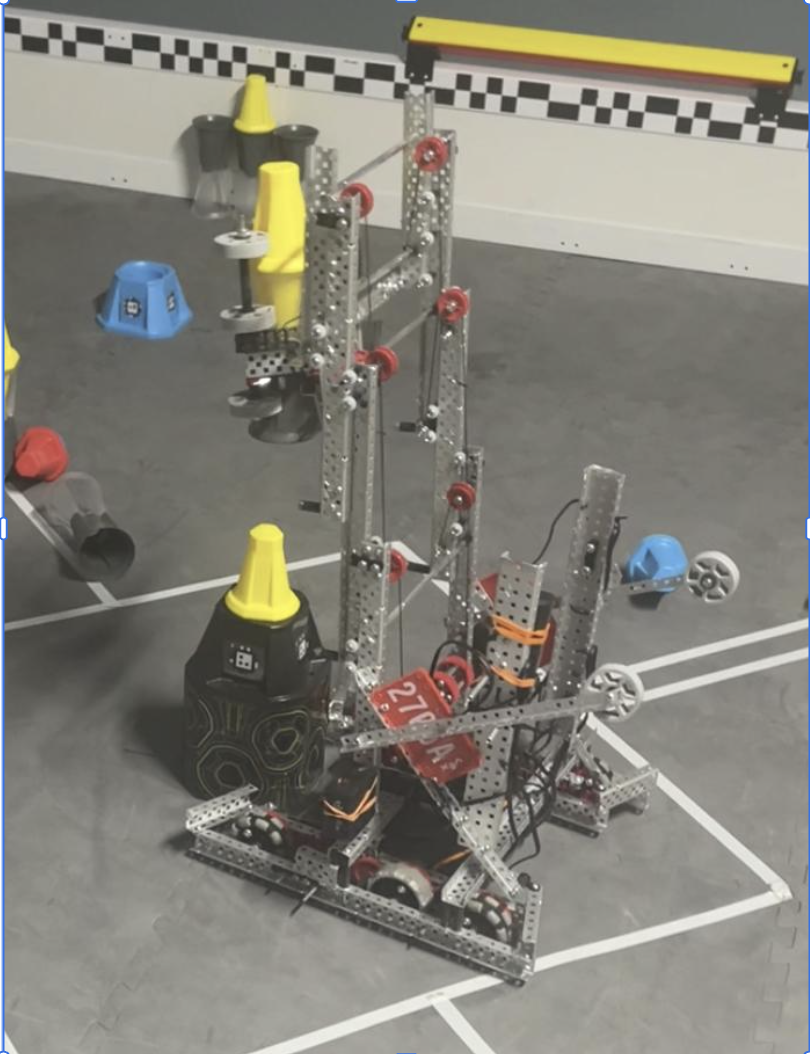
Our season Override began in July, when we built a DR4B lift (a double reverse four bar) and learned how much goes into getting even one part right. It took us several tries. The sides were spaced wrong, the gears did not line up, and one side kept lifting off the base. It took us multiple iterations on design, but we kept fixing it until it worked. Our first competition showed us where we stood. Our DR4B kept getting stuck, our gears slipped when the robot was working hard, and we were slow to score. Watching the other teams helped a lot. The best robots had cascade lifts that moved fast and rarely jammed, and claws that picked up game pieces quickly. This experience helped us understand our strengths and weakness . So we redesigned the robot. We built a new drivetrain with stronger motors and 2.75 inch wheels, mixing omni and traction wheels so it turns smoothly and still has the grip to push. We replaced the DR4B with a cascade lift, which goes up quickly and is simpler to build, and we are watching for tipping now that the lift is taller. We also built an intaking ratchet claw that grabs and releases game pieces without needing perfect driving. A local scrimmage gave us a chance to test everything and learn from others. We switched to a passive toggle design, and it worked better than our first idea. We also met an experienced member of a VEX AI team, who showed us how to string our cascade lift the right way, which had been one of our biggest problems. With his tips and some new spacers, we rebuilt the lift and restrung it, and it now moves much more smoothly. We then added rubber bands to the claw so both sides open and close evenly. Our mentor, Joseph Lipper, who ran our summer camp, checks in about once a month, or whenever we need help. We go over what is working and what is not, and then we get back to work on our own. We are still testing and improving. For the rest of the season, we want to make our autonomous program work every time, compete in as many tournaments as we can, win awards, and try to qualify for the VEX World Championship.